
You can just update ins and outs
1792 réponses à ce sujet
#1721

Mike118
-
- Administrateur
-

- 12 871 messages
Staff Robot Maker
- Gender:Male
- Location:Anglet
- Interests:Robotique, Entrepreneuriat, Innovation, Programmation, Résolution de problème, Recherche de solutions, Mécanique, Electronique, Créer, Concevoir
Posté 22 février 2026 - 18:55
Si mon commentaire vous a plus laissez nous un avis ! 
Nouveau sur Robot Maker ?
Jetez un oeil aux blogs, aux tutoriels, aux ouvrages, au robotscope aux articles, à la boutique et aux différents services disponible !
En attendant qu'une bibliothèque de fichiers 3D soit mise en place n'hésitez pas à demander si vous avez besoin du fichier 3D d'un des produits de la boutique... On l'a peut être !
Si vous souhaitez un robot pilotable par internet n'hésitez pas à visiter www.vigibot.com et à lire le sous forum dédié à vigibot!
#1723
firened
-
- Membres
-
- 2 124 messages
Pilier du forum
- Gender:Male
Posté 22 février 2026 - 19:34
Easiest is to just split the servo cables and connect to GPIO instead of writing code to use the i2c registers.
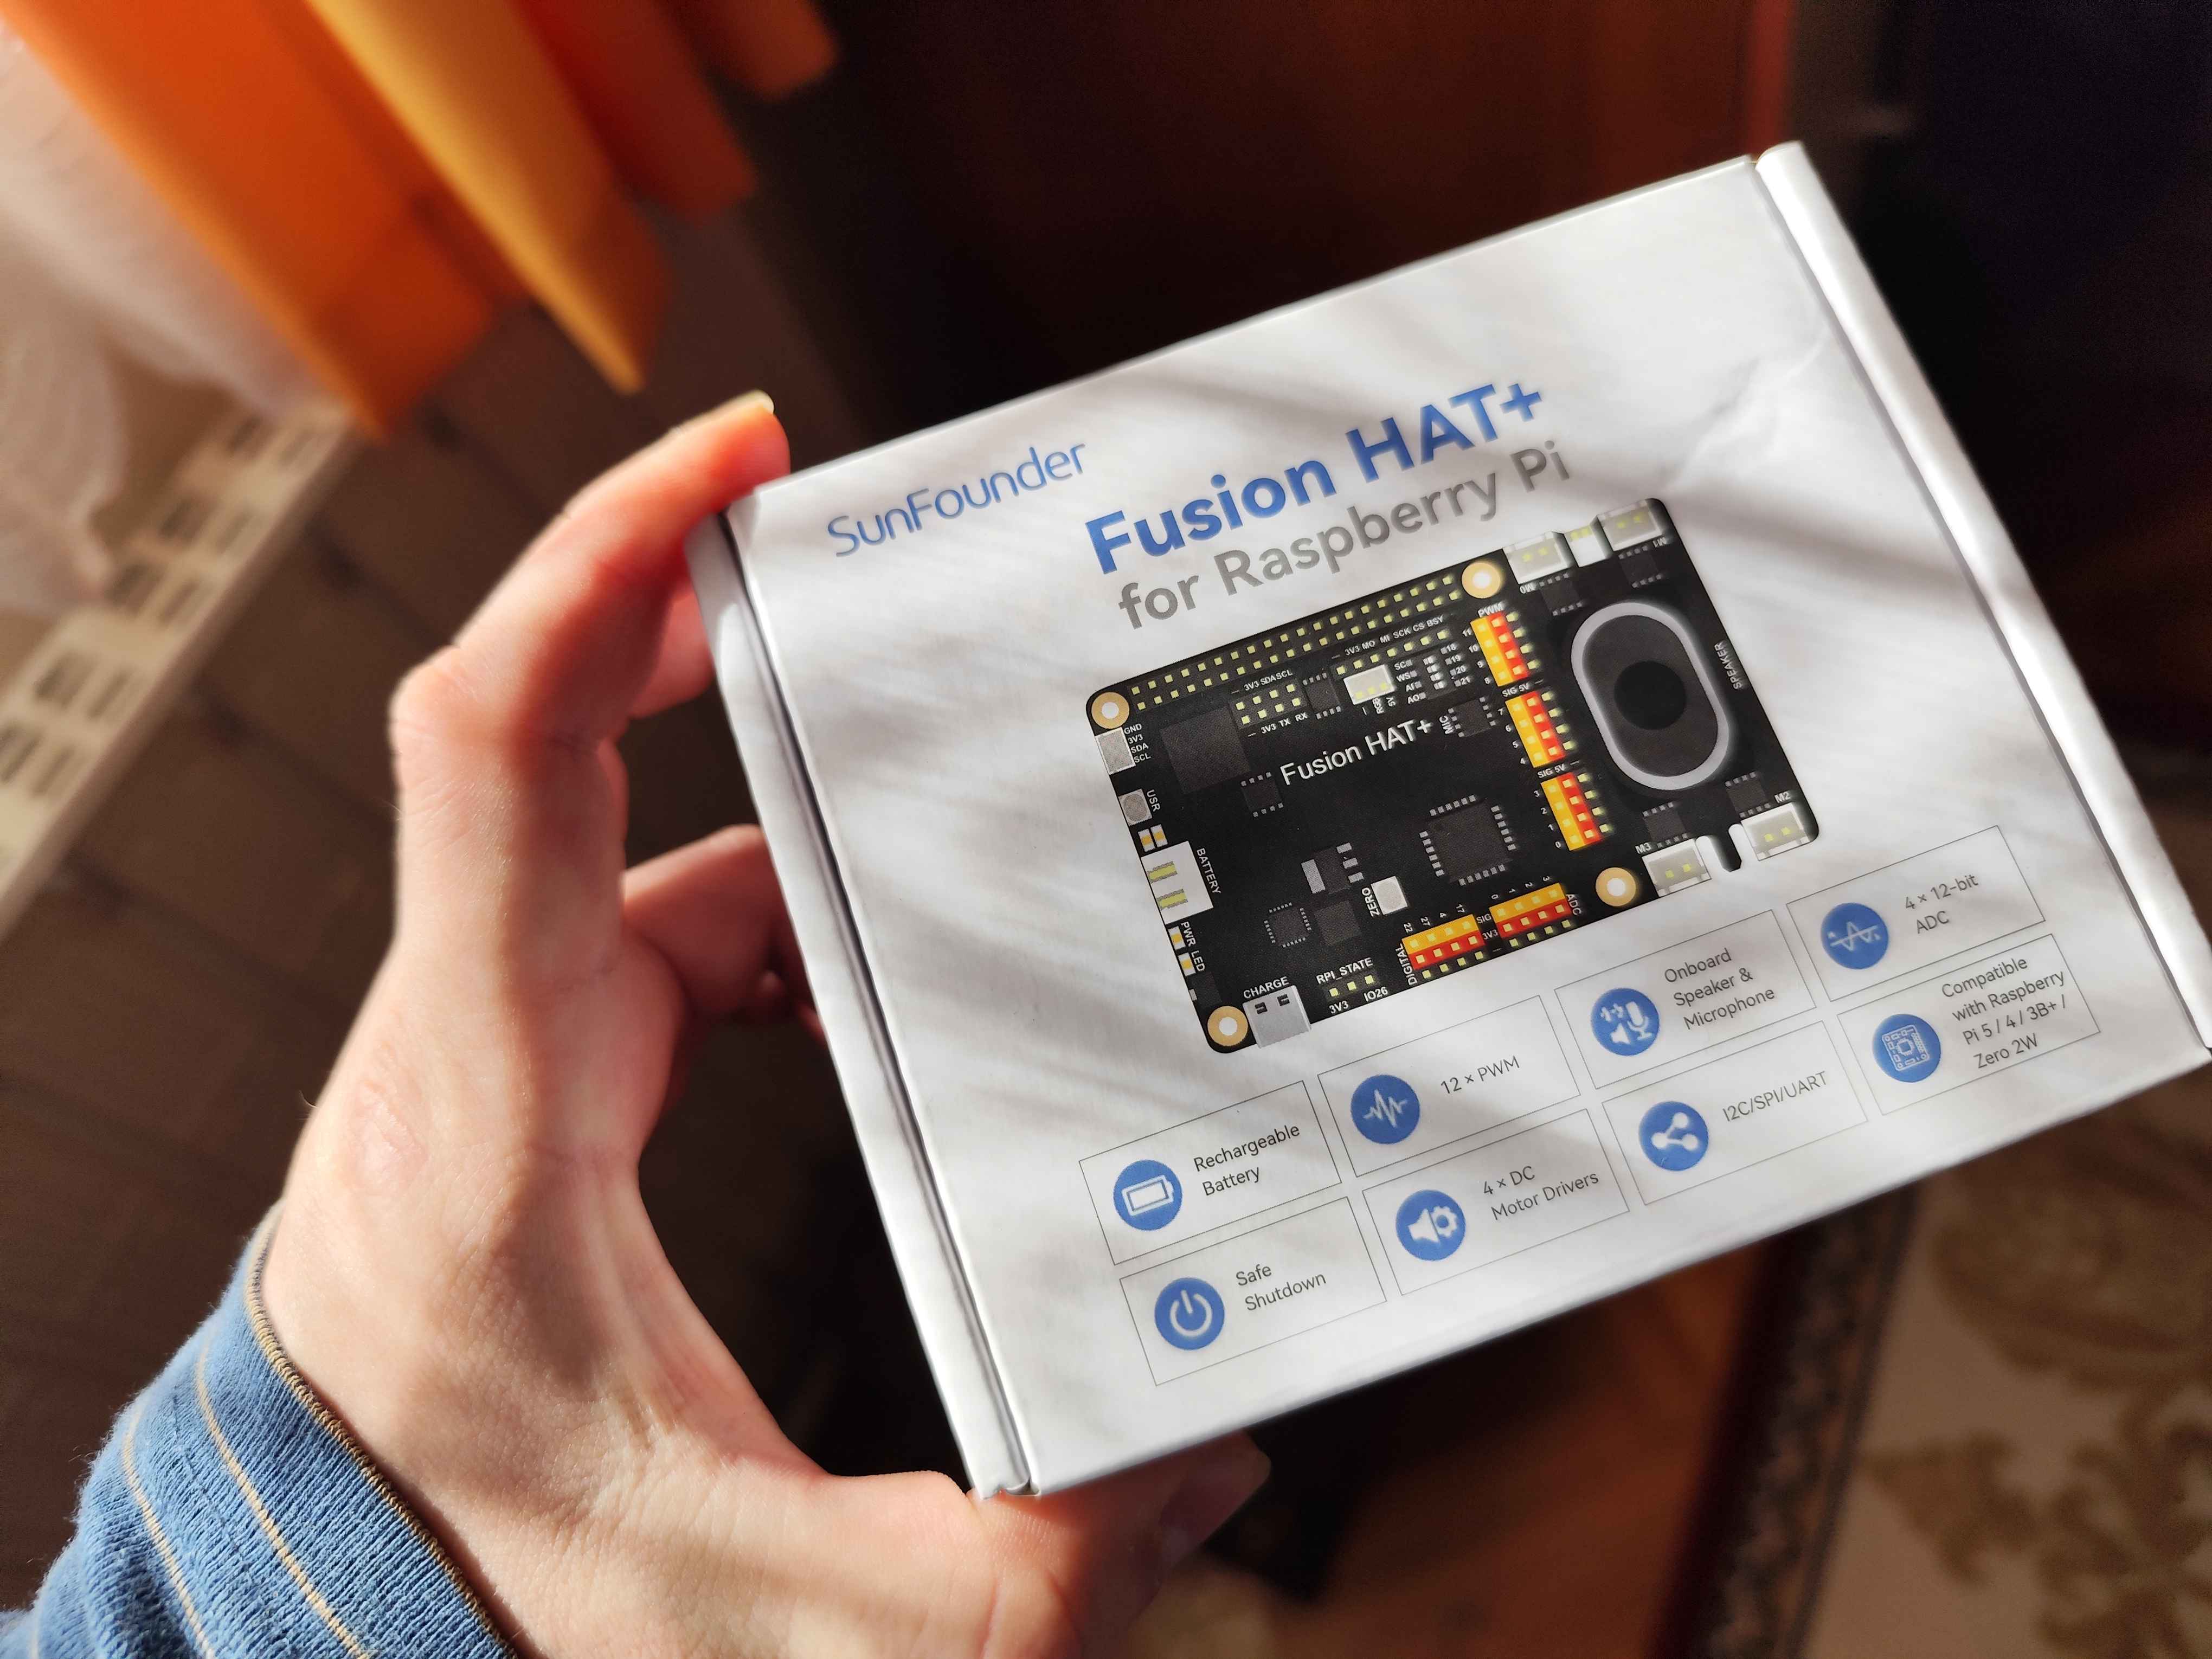
However the speaker and mic would be the most interesting to test. I wasn't able to get it working yet. I wonder if it has a gpio conflict with the Vigibot client.
@Garfield2142 if you get it, if you want you could try to get the speaker working on an fresh Raspbian install without Vigibot.
You'll have to edit the sunfounder install script because it tries to do some things that fail, like installing picoTTS over apt....
#1724
ralph_62550
-

- Membres
- 11 messages
Nouveau membre
Posté 23 février 2026 - 21:22
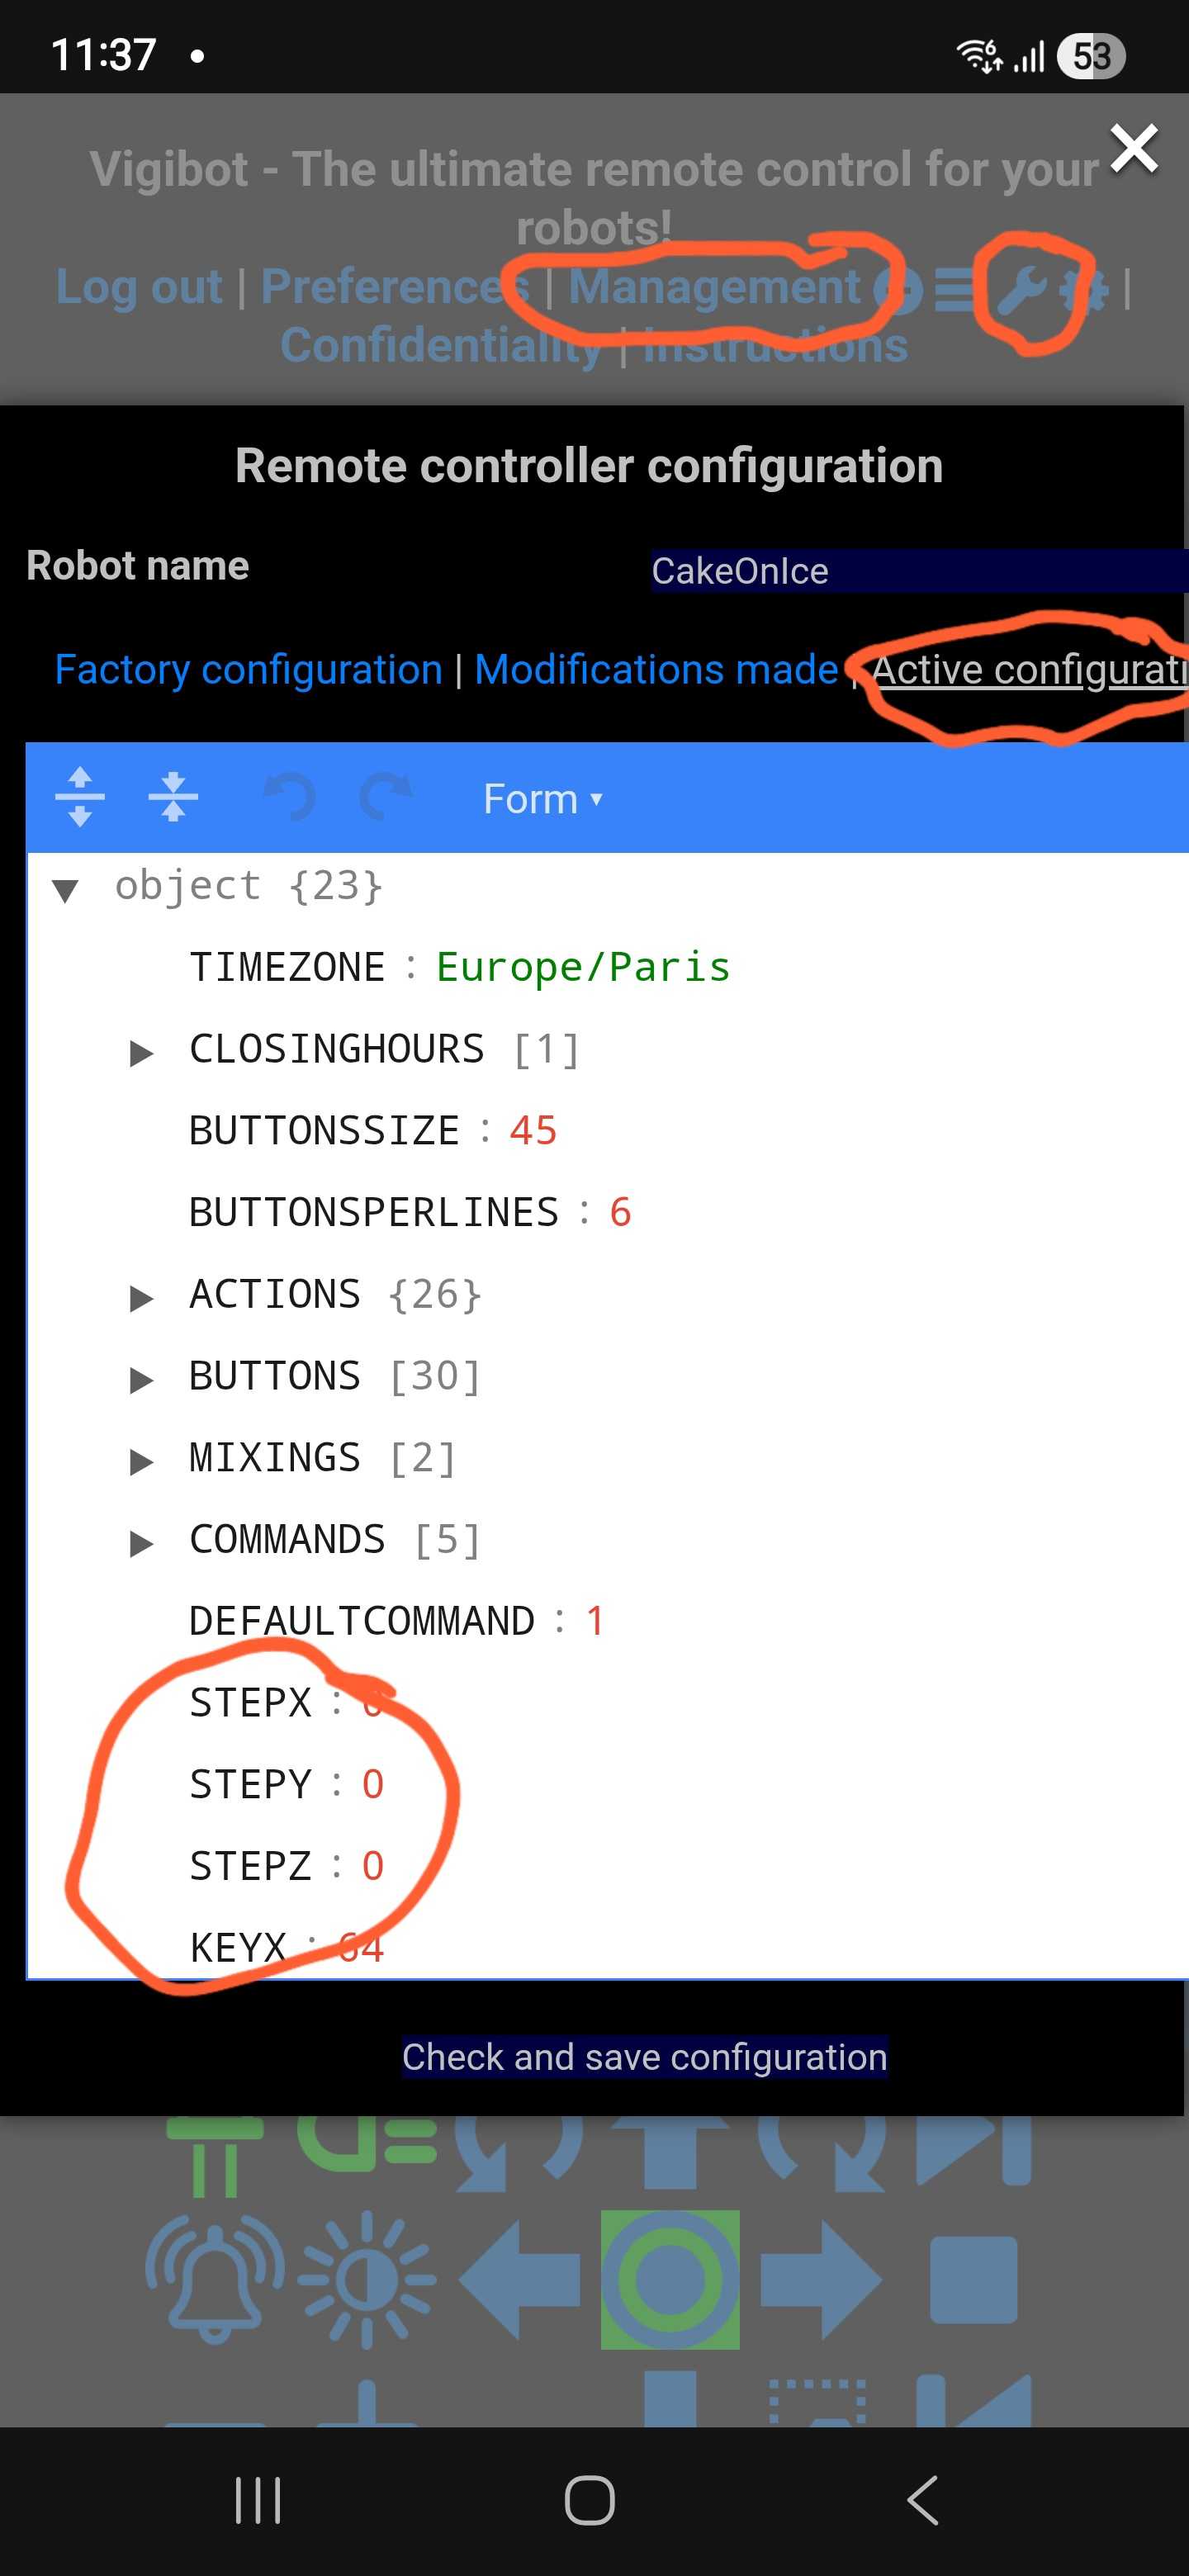
I couldn't find a file with a STEPY value inside. However I could make some adjustments in the hardware configuration with the "OUTS" values for "Left wheels" and "Right wheels".
But it is still a bit frustrating with those values for several reasons: frist you have to sacrifice the lowest possible speed and second there is even a dependency of the battery voltage. I had a running configuration. But after the voltage dropped a bit the problem reappeared, one of the motors wasn't starting with the lowest speed.
It is clearly a mechanical problem of at least one of the motors. Maybe I try to apply a bit of oil in the gear box?
You wrote that the roboter is rarely controlled using the pulse key. In my opinion it doesn't which input device is used to control the speed (at least if the slowest possible speed is the same for all input methods).
#1726
firened
-
- Membres
-
- 2 124 messages
Pilier du forum
- Gender:Male
Posté 24 février 2026 - 11:46
Adjusting STEPn might be the best option in my opinion.
Scenarios to consider:
- robot may be on an in- or decline. Driving forward may need a very small amount to move.
- when driving forward with the joystick, it must be possible to apply tiny left and right commands or driving will become frustrating. -> Preferably no INS or OUTS adjustments.
- i use the pulse key as autopilot. I click the pulse key multiple times forward and then add 1-2 clicks left or right depending on terrain (floow may not be level). If you increase the minimum PWM, using it like that would not be possible anymore, since it'll turn too fast.
#1727
ralph_62550
-
- Membres
- 11 messages
Nouveau membre
Posté 24 février 2026 - 14:38
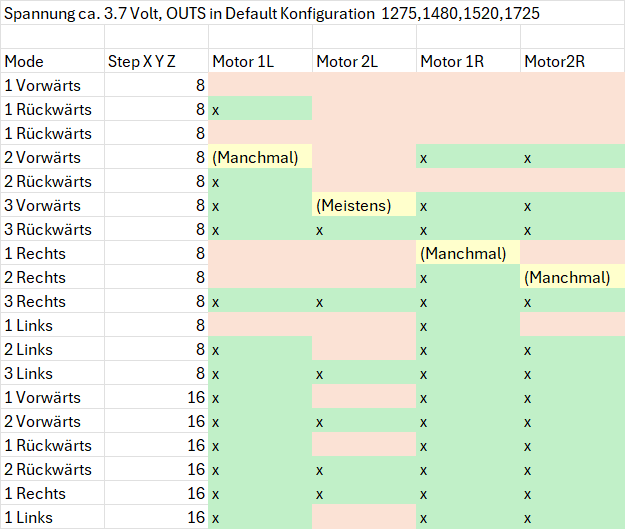
That's how it looks like. It makes a difference how long you wait between different tries. It looks like when the motors just have turned before the chances are bigger that they turn with lower steps. Motor 2L is the one with the biggest starting difficulties.

#1730
Mike118
-
- Administrateur
-
- 12 871 messages
Staff Robot Maker
- Gender:Male
- Location:Anglet
- Interests:Robotique, Entrepreneuriat, Innovation, Programmation, Résolution de problème, Recherche de solutions, Mécanique, Electronique, Créer, Concevoir
Posté 24 février 2026 - 15:33
You can also check the solder. This can have a visible impact.
Si mon commentaire vous a plus laissez nous un avis !
Nouveau sur Robot Maker ?
Jetez un oeil aux blogs, aux tutoriels, aux ouvrages, au robotscope aux articles, à la boutique et aux différents services disponible !
En attendant qu'une bibliothèque de fichiers 3D soit mise en place n'hésitez pas à demander si vous avez besoin du fichier 3D d'un des produits de la boutique... On l'a peut être !
Si vous souhaitez un robot pilotable par internet n'hésitez pas à visiter www.vigibot.com et à lire le sous forum dédié à vigibot!


Répondre à ce sujet


1 utilisateur(s) li(sen)t ce sujet
0 members, 1 guests, 0 anonymous users

